
GPT-6 Astra Drives a Real Toyota Corolla in DrivingBench
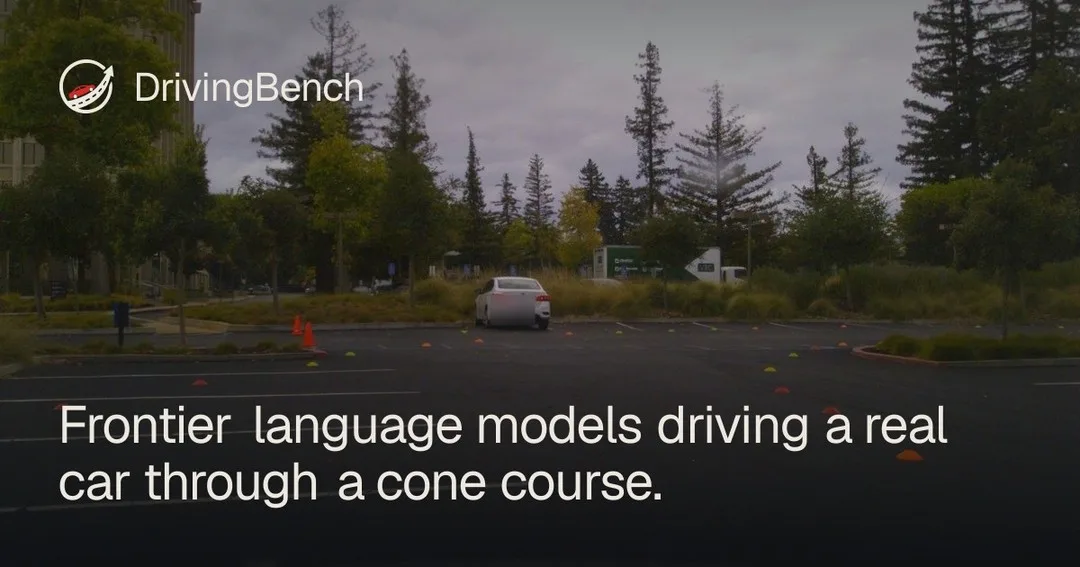
Ever wondered how a frontier language model handles an actual steering wheel? Three researchers bolted a control system into a Toyota Corolla and wired it straight into an LLM interface. The result is DrivingBench, and the gap between the models is the interesting part.
The car takes in visual and spatial data and sends back one control command per action: steering, gas, or brake. A human sits in the front seat the whole time, foot near the brake, ready to take over the moment the system drifts.
What Happened
GPT-6 Astra, Grok 4.6, Claude Fable 5.1 and GPT-5.6 Sol all ran the same route. It is not driving the way an ordinary autopilot does, because the model reasons through the situation and then issues a single command at a time.
The sticking point was latency and consistency in spatial reasoning. Grok 4.6, Claude Fable 5.1 and GPT-5.6 Sol all hit the cones marking the route boundary, because tiny deviations piled up faster than the models could correct them.
Astra cleared the full route on attempt 2, thanks to a tighter spatial reasoning loop, finishing in 5 minutes 22 seconds.
Why It Matters
The short version is that a foundation model can now hold a real car on a real route, not just in a simulator. That is a meaningful step for applied robotics built on top of models like these.
The catch is the word supervised. A person is still in the car with a hand ready, and the whole run rests on a human being able to step in. Think of it as a promising experiment with a safety net, not a car you could send out on its own.
Does this still work?
Nobody's checked yet
Sign in to tell everyone how it went.
Continue with GoogleBe the first — one tap saves the next person an hour.
It takes 3 reports in 30 days to set the status.
More shares you might like
 NewsTanStack Start 1.0 Is Stable4h9 views
 AIDolphin 2.9.2 Runs Uncensored Llama 3 8B on 6GB VRAM4h11 views
 NewsDeepSeek V4 Pro Is a 1.6T Open-Weight Model With a 1M Context16h24 views
 AIHermes 3: An Uncensored 70B Model That Runs on Two GPUs16h19 views
 NewsOpenCode 2.0 Ships Background Tasks and Subagents1d20 views
 AIAlibaba Reveals Qwen4 Series: Max, Plus, Flash and 27B1d27 views

Comments
Join the conversation — sign in to comment.
No comments yet — start the conversation!